
web api instance method
OrientationSensor: populateMatrix() method
Secure context
The populateMatrix() method of the
OrientationSensor interface populates the given target matrix with the
rotation matrix based on the latest sensor reading. The rotation matrix is shown
below.
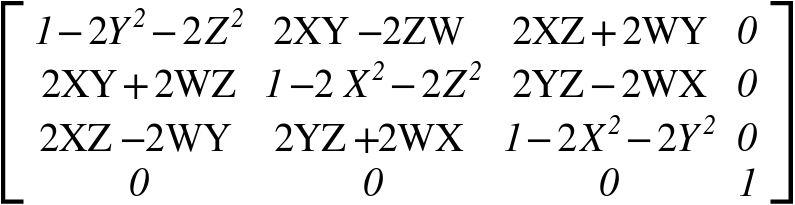
where:
- W = cos(θ/2)
- X = Vx * sin(θ/2)
- Y = Vy * sin(θ/2)
- Z = Vz * sin(θ/2)
Syntax
populateMatrix(targetMatrix)
Because OrientationSensor is a base class, populateMatrix
may only be read from one of its derived classes.
Parameters
targetMatrix- : TBD
Return value
None (undefined).
Examples
// TBD
Specifications
SpecificationsStandards references are available on the canonical MDN page.
Browser compatibility
Browser compatibilityCompatibility data is available on the canonical MDN page.